

Rice
Rice
Zhang Wenyu1,2,3Wu Sijin1Zhigang Zhang1,2,3Ding Fan1,2,3He Jie1,2,3Hu Lian1,2,3Luo Xiwen1,2,3 *
(1, Guangzhou 510642, China;2Lingnan Modern Agricultural Science andTechnology, Guang
State 510032;3Key Laboratory of Agricultural Artificial Intelligence of Guangdong Province, Guangzhou 510642, China;*Correspondence Author)
Abstract: With the deepening of the aging of China's rural population, the improvement of riceproduction intelligent level is urgent, among them, the intelligent harvest linkneeds are particularly urgent, and difficult to achieve.At present, the intelligent rice harvester is in operation due to the limited capacity of the granary.industry has seriously affectedoperational efficiency.In view of this problem, this paper combines the current situation of domestic and foreign research, systematically combs the key of the two collaborative operation modes of fixed-point unloading grain and following the truck unloading grain.technology research progress.In terms of fixed-point grain unloading technology, through the use of high-precision space.geometric modeling, parking distance compensation prediction and stereo vision detection technology, realhas a precise alignment with a longitudinal deviation of less than 0.20 m and a transverse deviation of less than 0.10 m, which effectively improves the accuracy and efficiency of grain unloading.is following the car to unload foodPrescription, based on the improved inter-machine communication protocol (using radio/4G dual mode) and Kalman filtering delay compensation method, the communication error is successfully reduced.82.00 percent.At the same time, combined with the gain self-adjusting single neuron control algorithm,enables the dynamic synergistic longitudinal deviation to be stably controlled within ± 0.08 m, significantly improving the following truck unloading.stability and reliability. In terms of path planning, this paper constructs a multi-objective optimization model based on improved ant colony algorithm.simulation results show that, using the modelcan improve the efficiency of collaborative work by 13.58, further optimizing the harvest process.By integrating the above technologies, the collaborative system builtenables the rice harvestefficiency reaches 0.42hm2/h, compared with stand-alone operation efficiency increased by 26.00. However, existing research results in complex farmland environment adaptability and irregularblocks. In the future, we need to further strengthen the system's Lu.Stick, and conduct multi-scenario verification work to drive smart rice harvestingtechnology.
: rice; intelligent harvesting; high-precision alignment; cooperative grain unloading; path planning; machine-to-machinecommunications; unmanned farms
: S511.091 Document Identification Code: A Article Number:1006-8082(2025)04-0057-07
Based on the high-precision Beidou satellite positioning system (BDS), inertial navigationsystem (INS) and multi-sensor fusion technology, intelligent rice harvesterAutomatic operation harvesting capability with centimeter-level accuracy[1]. However, due to the receivingThe capacity of the granary is limited, and the harvest needs to be interrupted frequently during the operation.performed, which greatly affects the efficiency of the harvesting operation. Needleon this issue, researchers at home and abroad around the process of grain unloading and transportationcollaborative control, path planning and operational strategy are opened.showed up.related research.NOGUCHI, etc.[2]Divide agricultural machinery collaborative work into fixed-point associations.the same and follow the two modes of collaboration. Purdu University of AmericaLIU, etc.[3]Design, which can root.According to the relative position of the two cars, it automatically controls the expansion and return of the unloading barrel.received.Kingin and so on[4]first proposed an electronic control system for unloading grain based on visual inspectionand self-correcting grain unloading control methods, using the camera vision system to achieve the right.of the position of the grain unloading port of the harvester and the speed of unloading grain.regulation. Yao, etc.[5]for the same type of agricultural machinery collaborative work path planning research.study, through path optimization simulation conflict-free collaborative work scenarios, optimize the total.job time. The simulation results show that in rectangular farmland, the total operating time is flat.were reduced by 2.45 and 2.29 per cent. Cao Ruyue, etc[6]Proposedbased on improvement A *algorithm andBeziermulti-machine collaborative global path planning method,.effect reduces the number of turns. Gong Jinliang et al[7]Association for agricultural robot groups.the same job, through improved genetic algorithms and deep-first search (DFS)algorithm, the task allocation and path planning are optimized, and the robot group is improved.operational efficiency and coverage quality.ZHANG, etc.[8]designed a method based on

(a) fixed-point grain discharge(B) Unloading food with truck
Figure 1Typical Cooperative Grain Unloading Mode
Arduino intelligent vehicle control system and based on XBeeself-organizationline network realizes the centralized control of the upper computer, which can control the vehicle speed, vehicle speed and vehicle speed.vehicle spacing and vehicle queuing for regulation. Li Shi-Chao et al[9]designed abased onTD-LTEmulti-machine collaborative navigation and communication system to achieveserver and the vehicle terminal.The system uses 4Teiwo(LOVOL) Tractor as test platform, the state of each agricultural machineinformation transmission frequency is 5Hz, and the system stability test.
currently, the production is formed as shown in the figure1 shows two typical synergeticoperation modes, namely fixed-point grain unloading mode and following-vehicle grain unloading mode. These two models

Date of receipt: 2025-05-30
Fund Project: Guizhou Science and Technology Plan Project (Qiankehe Support [2024]100);National Key R & D Program(2022YFD2001601); Guangdong Provincial FoundationFoundation and Applied Basic Research (2025A1515012286); ShandongProvincial Key R & D Program Projects (2022SFGC0202)
 (a) Schematic diagram of alignment of harvester and grain truck(B) Geometric relationship of double-machine precision alignment
20
15
dv/m |
5
0
-5
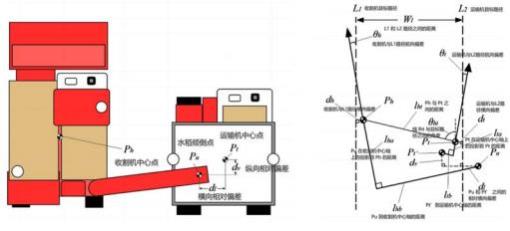
Figure 2 Spatial geometry model of precise alignment and unloading of grain by harvester and grain carrier
ed/m |
t/st/(s)
(a) Relative longitudinal deviation test results(B) Relative lateral deviation test results
Fig.3 Field harvest test results of fixed-point grain unloading
has its own advantages in different operating scenarios and has become the current food harvest.operations 0 1fixed-point grain unloading fixed-point grain unloading mainly covers fixed-point parking and automatic unloading.two aspects of grain 0fixed-point parking provides precision for automatic grain unloading operations.is guaranteed, while the automatic unloading of grain is based on precise parking.Help the intelligent system to automatically complete the grain unloading process 0 1.1parking alignment Due to the complex and variable farmland environment, there is a high delay in control, and the agriculturalmachine parking inertia is larger,The relative position between the harvester and the grain truck is difficult.for precise control 0this often leads to the harvester in the fixed-point unloading mode.is not accurate, and the alignment deviation is large 0 Therefore, how to achieve highprecision of fixed-point parking alignment is to achieve the goal of fixed-point grain unloading and improve coordination.Harvest Efficiency 0ZHANG, etc.[10]Synergy through in-depth analysisthe geometric relationship between the crawler harvester and the grain truck in the process of unloading grain,Build.the model willcollaborative controlprocesses are decoupled in both horizontal and vertical dimensions,respectively through the controlvehicle steering and parking to achieve accurate alignment 0Research Teamfurther kinematics and dynamics models of harvesters and grain trucks are constructed,include.. |
Based on the above model analysis,research team designed a parking-basedthe longitudinal controller of the compensation prediction,as well as based on improved pure trackingmodellateral controller,Successfully Achieve Accurate Parking Alocation and Collaborative Point Unloadinggrain 0 field harvest test are shown in Figure 3.degree less than 0.20m, lateral accuracy less than 0.10m0
1.2automatic grain unloading
CUI, etc.[11]constructed a set of tracks based on stereo visiontype ricecombine harvester automatic grain unloading system, and developed a corresponding implementation flowprocess 0they proposed the method of obtaining the expected unloading point based on instance segmentation, the base.on geometric position information, and based on unloading grain.the elevation angle of the cylinder 0 in addition., also developed amethod based on mapping model of grain pile height and unloading time, for estimationthe unloading time of each expected unloading point, which is finally completed by controlling the unloading cylinderGrain unloading operation 0test show that the calculated value is in line with the actual expected grain unloading point.is less than 3.10cm,The maximum relative error is less4.00 percent; the maximum absolute error between the expected and actual unloading points
58
less than 3.70cm, the maximum relative error is less than 4.00 per cent;Bin depthand its true value is 1.40cm.,root mean square error is1.70cm; actual grain dumps at each unloading pointheight andexpected grain heap heights is1.20cm,root mean squareerror is1.40cm. During the whole process, the harvester automatically unloadsGrain Systemand its execution process exhibit a high degree of stability and reliability,and hasHigh precision, fully meet the requirements of automatic unloading.
2follow the car to unload grain
collaborative harvesting operations is high,Involving path tracking controlsystem, inter-machine communication, path planning and job scheduling, collaborative job control.and machine control and other links.Among them, path tracking control is the intelligent agricultural.machine equipment;path planning and job scheduling arecontrol decisionprovides a baseline basis; inter-machine communication provides a guarantee for collaborative control; collaborative controlsystem provides the core control basis for collaborative harvesting operations.
2.1Inter-machine communication
compared to the parking alignment in fixed-point grain unloading,following the car to unload grain requirementsThe acquisition and transportation vehicles travel simultaneously, real-time alignment and coordinated unloading of grain. in the actualoperation, signal interference, transmission distance, transmission speed and delayand other issues will affect the real-time collaborative control effect.Therefore, to ensure that dualis the guarantee of the smooth unloading of grain with the truck.prerequisites for progress.In order to realize the high frequency of unloading grain with the truckand effective inter-machine communication,DING, etc.[12]by analyzing the autonomous harvesting processharvesters and grain trucks in real-time vertical alignment and precise unloading of grain.communication needs,design the wireless communication protocol. They choose radio and4G two different wireless communication modes to achieve inter-machine communication, and proposedBased on Kalman filter and delay compensation method, the inter-machine communication datareal-time processing, compensation and correction. The verification test results show that the card-basedErman filter and delay compensation method can stably update the harvester and.the relative longitudinal distance between grain trucks. Compared with the reference value, using the stationcommunication is 3.78cm,standard deviation is 0.39cm;Maximum absolute error is 7.38 when using 4G communicationcm, the standard deviation is1.32cm.Compared with not using this method, the maximum when using radio communication.absolute error is reduced by 82.29, variance is reduced88.76 percent, using 4Gcommunication, the variance decreases90.60 percent. This shows that the method effectively solves the problem of packet loss and wireless communication.delay problem, and has a certain breakpoint endurance in a short time. Twowireless communication modes can complement each other,for design redundancyin the collectionacquisition and grain delivery vehicles. Table of Actual Harvest Operation Results in FieldMing,The relative longitudinal distance between the harvester and the grain truck is the same as the reference value.ratio, with a maximum absolute error of 4.86cm, the standard deviation is0.54cmand more.new frequency can always be synchronized with the control frequency. This method can be effectivecontrol, to adapt to the requirements of field operations, to protect the harvester andThe grain truck follows the truck in real time and accurately unloads the grain.
2.2dynamic collaborative control
with a stable base for inter-machine communications,in the field ringenvironmentco-control is a key challenge for unloading food with trucks..currently, for farmersmachine cooperative operation control has made some progress,Main Method Packageincludes sliding mode variable structure control, proportional-differential control, state feedback and.disturbancefeedforward combined control strategy. In addition, some studies also introduce predictionsmodel control, linear matrix inequality optimization control and other control theories to advance.one step to improve the accuracy and robustness of collaborative control. However, many of these studiesfocuses on the constant speed cruise control of agricultural machinery and the speed adaptation of the combine harvester.should be aspects, and the control accuracy and adaptability need to be improved.
ZHANG et al[13]based onleader-follower designed dual navigationfollowing system, aiming at the relative position error of the two machines when working together in the field,designed.PDthe controller to maintain the distance between the two machines,and made a safecooperative turning method. Field operation test results show that when the tractor speedfor 0.83m/s, the minimum distance between the two tractors is 4.09m,the minimum distance between two safe areas is 0.59m;when the tractor is madeone path to the next,Waiting in the course of a turn aroundtime is 18.20 s. Compared with single tractor operation, dual systemefficiencyincreased by 95.10 per cent, proving that the master-slave tractor system works in the field..
Bai Xiaoping[14]propose a receiving based on the pilot-following structure.cooperative navigation control strategy for the acquisition fleet. They combine feedback linearization as wellthe sliding mode control theory and the kinematic model of the harvester group, the path tracking is designed.and formation-keeping control methods,and integrated development of the joint harvestMachine Group Associationwith the navigation system.to verify the effectiveness of the proposed model, method and system,The field was carried out with a group of 4 harvesters as a test platform.test.results show that when the velocity is1.00m/s, the pilot harvesteraverage tracking error of 5.81cm, following the average tracking error of the harvesterfor 5.93cm, similar to the navigation control accuracy of a single harvester, proof.
Zhang Wenyu et al[15]Coordinated grain unloading operation process for master-slave navigation harvestingtractor-trailer following wheel combine harvester for harvesting-grain unloadingthe operation scenario (Figure 4a), by controlling the throttle and engine speed, setA vertical is used for the main-from-navigation collaborative harvest unloading operation.relative position collaborative control method.they are based on the co-system geometryobtaining a parallel synergy model of the longitudinal relative position deviation, based on the dynamicsprinciple and bit-speed coupling control method to design the longitudinal relative position control, the vehicle speed system transfer function is obtained by area identification method, based on.transfer function to build a simulation model for full-factor simulation of controller parameters.optimization test, and with the traditionalPID(proportional-integral-derivative) method. The results show that the adaptability of the control method is good.different initial deviations show that inhost speed is1.00m/s, 3, 7 and10m under initial longitudinal deviation,
system response is 7.73 and 17.20 respectively.and 23.20S,mean steady-state absolute deviation of 9.18cm, mean relative velocity steady-state error1.23cm/S. Field collaborative harvest experiments show that the speed of the harvester is1.00m/S, the absolute value of the average steady-state longitudinal relative position deviation is7.78cm, with a standard deviation of 9.13cm, control accuracycan meet the collaborative income.the operational requirements for obtaining grain unloading.
DING, etc.[16]For tracked grain trucks to follow the combine harvesterline-to-car unloading scenario (Figure 4b), by analyzing the hydraulic stepless speed change junction.structure and mathematical model, identification of hydraulic stepless speed-speed system transfer letter.,Research IncrementalPIDand gain self-tuning single neuron adaptivePIDcontrol method, as well as the vertical relative position of the two-machine collaborative control imitation.the establishment, research and analysis of the true model, combined with path planning and path tracking.control, the control of the relative position of the crawler harvester and the grain truck is realized,and verified by experiments.Simulation Test and Control Performance Comparison Test TableMing,gain self-adjusting single neuronPIDcontrol method compared to the incrementalPIDmethod has better control accuracy, convergence performance, speed adaptabilityand anti-jamming capability.field performance test experiments show that when the harvester (mainmachine) speed for 0.60, 0.80 and1.00m/S, use gainself-adjustmentsingle neuronPIDcontrol methods,Accelerate alignment and reduction in the grain truck, respectively.speed under two kinds of para conditions,harvester and grain truckmaximum overshoot does not exceed 0.25msteady-state mean absolute deviation is notover0.08m, the maximum deviation of steady state does not exceed 0.26m, stablestate standard deviation does not exceedover 0.09m, with good initial position and speed adaptability.fieldshows that when the harvester speed is 0.80m/S, transportGrain trucks and harvesters require an average of 13.20 to complete alignment.S, the maximum overshoot is0.22m; after entering the steady state, the standard deviation of the longitudinal deviation is 0.09m, flatmean absolute deviation is 0.07m, maximum deviation is 0.25mto meet the requirements of precise unloadingthe requirements of grain operations,grain can be accurately unloaded to the grain truckin the warehouse.
3Path Planning and Job Scheduling
path planning and job scheduling provide benchmarks for control decisions.In order to realize the cooperative operation of the harvester and the grain truck, improve the efficiency of the operation.has important research value.LI, etc.[17]With harvesters and grain trucksand unloading operations as the application scenario, in order to achieve the shortest operating time of the unit, work.the goal of optimal efficiency and optimal economy in the industry,study the multi-constraint. Specifically, theythree steps to build a harvester and grain truck multi-machine collaborative operation of intelligent scheduling.model, and explore the intelligent solution method of multi-objective optimization model. Herebasis, a method based onNSGA-III(third generation non-dominant platoonsequential genetic algorithm)and improved ant colony algorithm for intelligent schedulingtarget optimizationalgorithm. Finally, the established intelligent scheduling model is verified by simulation experiments.and solution methods can effectively solve multi-objective combination optimization problems and.. however,

(a) Wheeled harvester-tractor trailer system(B) Crawler harvester-grain cart system
Figure 4 Harvester-Grain Truck Collaborative Harvesting-Grain Unloading Test Scenario
the current study only conducted simulation tests for regular rectangular plots, yetdid not carry out the study of different shape plot boundary and field experiment test.
WANG, etc.[18]for different types of farmers in the harvest transfer operation scenario.machine equipment scheduling problem, farm-based high-precision electronic map, analysisthe characteristics of grain unloading in the land area, aHU-HUPGAalgorithm(Harvester Unloading Point Generation and Adjustment Algorithm). Combined with harvest transfer scenariospecific needs, they established a multi-farm machine scheduling model and proposed a base.inHGHI(hybrid genetic and heuristic iteration) algorithm is advanced., a collaborative scheduling planning method for harvesters and grain trucks is designed. tohigh-precision electronic map of the actual farm to verify the simulation scenario., the results show that the proposedHU-HUPGAalgorithm can realize agriculturalmachine harvesting and transshipment scenarios enables effective generation and adjustment of unloading.grain point, and the generated grain unloading points are located in the headland area., all points of unloadingis less than the set capacity of the harvester granary, meeting the actual demand,.good feasibility and adaptability. However, the method relies on pre-constructed farmers.field map data, to a certain extent, ignores field obstacles, path, agricultural machinery failure and how to combine with real-time collaborative control and other issues.
Man Zhongxian et al[19]To improve multiple unmanned intelligent harvesters and grain transportationthe cooperative working efficiency of the vehicle, with 2 different models of rice harvesters and1 grain truck as the research object,Control decisions based on collaborative work.beam conditions,established a limited number of state processes in collaborative harvest operations.progressive continuous-time Markov chain model,to reduce non-operating timeoptimization goals. The model is used to predict each harvest over a period of time in the future.machine,dynamically update the unloading sequence and time of each harvester, a multi-machine collaborative harvesting operation method was designed, and a simulation of Hotan was carried out.inter-harvest test. The simulation test shows that the control method is compared with the warehouse full.and then summon the grain truck to unload the grain, effectively reducing the operation time, coordination.harvesting tasks was reduced13.58 percent. field harvestacquisition test showed that,This method realizes 2 rice harvesters and.1 unitgrain trucks can reduce the non-operating time of the harvester.one step to improve the efficiency of harvesting operations.
4
In recent years, intelligent agricultural machinery equipment has gradually become a research hotspot.Pathtracking control, inter-machine communication, collaborative work control and other aspects have achieved certainProgress, although there are still some shortcomings, but basically able to meet the synergistic harvestthe needs of the job. In the path planning and job scheduling, most of the research
only carried out simulation research, although it provides a goodtheoretical basis and research ideas,, there is still a certain gap from the practical application.Therefore, based on actual production needs and job scenarios, path planning andindustry scheduling, path tracking control, inter-machine communication, collaborative job control,machines and toolscontrol, the study of harvest-unloading-transport collaborative work methods,.It is of great significance to realize the independent harvest of the whole process and improve the efficiency of operation.
For rice harvester and grain truck double machine collaborative independent operation link, grain transfer process complex and other issues, Zhang Wenyu, etc.[20]designed aCooperative operation strategy of rice harvester and grain truck based on finite state machineslightly. They analyzed the cooperative operation mode of rice harvesters and grain trucks,, the finite state machine model is established. First of all, based on the operation link design touch.basic modules such as development conditions, evaluation methods, and execution processes; then, based onto the state of the two-machine collaboration; finally, based onthe logic of co-triggering events and state transitions,, the logical framework of time division multiplexing control for cooperative work is constructed.Adoption of shoesbelt collectionharvesters and grain trucks: Harvest speed 0.80m/s,Harvesting Width1.90m, continuous collaborative work time exceeds2.00h, adoptedferrule path autonomous harvesting0.70hm2rice, during which a total6timesfixed-point grain unloading and automatic cooperative transfer operations,and will harvest the grainfood transportto truck.results show that the strategy can achieve rice harvest/unloading.Operate independently, and the harvest efficiency is0.35hm2/h, realnow rice harvestlaid the foundation for the cooperative function of dual-machine transport.
on this basis,DING, etc.[21]proposed fixed-point grain unloading and truck unloading.grain,and based on these two grain unloading modelstype into onestep, the cooperative operation strategy of harvesting-unloading-transporting is designed. By decomposing the associationthe main phases of the same job and the design module state machine,built the state transitionshifting chain, solving the problem of multiple, non-sequential and strong coupling in collaborative harvesting operations.;and established a collection suitable for navigation control system.Harvest-Unload-transshipment collaboration.AdoptionMATLABSimulinkStateflow, it is simulated and verified, and the simulation results show that it is set.meter can realize the state actuator.state transition,can effectively describe the whole of the harvest-unloading-transport synergy.a process,and provides for further optimization and expansion.good foundationbasis.Rice Unmanned Farm in Zengcheng Teaching and Research Base of South China Agricultural Universityconducted a field harvest test: the test plot area was 5162.81m2, Harvestwidth1.90m, harvest speed 0.80m/s, synergisticHarvest-Transfer Systemcompleted the whole harvest, the test scenario is shown in Figure 5. during the harvest.carried out6 times following the truck to unload grain and 1 time fixed-point unloading grain, grain truck to the truck, and the harvest efficiency is 0.42hm2/h. The results show that the harvest-unloading.grain-transshipment collaborative strategy effectively integrates path planning, path followtracing control, inter-machine communication, collaborative work control and implement control. Harvesterparking and unloading food has been significantly reduced,its harvest efficiency than single1 Harvesterand 26.00 per cent, respectively, when only fixed-point unloading was used.9.90 percent.
to sum up,these studies
(c) fixed-point grain unloading after all the harvest (d) grain trucks unloading grain to trucks |
Figure 5 UAV aerial photograph of master-slave collaborative work site
and Synergistic Harvesting-Transshipment Systems for Synergistic Harvesting from Theoretical Models to Technologiesimplementation provides support,and provides a new harvest link for unmanned farms.solutions.
5Conclusion
This article focuses on the intelligent rice harvest operation because of the combined harvester granary.capacity and frequent interruptions of operations to the edge of the field to unload grain,explores in depth the two typical types of collaborative unloading, fixed-point unloading and truck unloading.grain moldkey technology. Through the analysis of the current domestic and foreign in the automatic unloading system,collaborative path planning, dual-machine collaborative control, communication systems and navigation algorithms, etc.research results,system summarizes the technical realization of each key linkpath and field test results, in order to improve the efficiency of rice harvesting operations, reducedowntime provides theoretical support and technical reference.
in fixed-point grain unloading,precision parking and automatic grain unloading systemresearch has made significant progress, especially in space geometry modeling, dynamic controller.design and recognition of grain piles based on stereo vision,all show good.good stability and accuracy, to meet the actual needs of field operations. Infollowing the truck to unload grain,By building a stable inter-machine communication system.System and High Precisiondegree relative position control strategy,realized combine harvester and grain trucksynchronous alignment and dynamic cooperative operation,preliminary validation of the collaborative control infeasibility and reliability in complex farmland environments.
although some progress has been made,, the current collaborative unloading system is stillfaces many challenges. First, the field environment is complex and changeable, uncertainty duefactors (such as terrain changes, agricultural machinery attitude fluctuations, communication signal occlusion, etc.)pair systemsystem puts forward higher requirements. Secondly, there is a lack of integration between multi-machine systems.One Job Scheduling Platform, compatibility, coordination between different agricultural machinery to befurther optimization. In addition, most of the existing studies are based on regular rectangular plots.line simulation and validation for collaboration in irregular parcels and multi-obstacle environmentslack of in-depth study of grain unloading mechanism.but with the intelligent agricultural machinery equipment technology
development, the future of rice harvesting operations will be more intelligent, efficientdirection. In-depth research and optimization of existing technologies to enhance field trialsand application,to promote the intelligent development of rice harvest links.is heavy.want meaning.
References
[1] Luo Xiwen, Hu Lian, He Jie, et al. Research and construction of key technologies for unmanned farms in Datian, Chinapractice [J]. Journal of Agricultural Engineering, 2024,40(1):1-16.
[2] NOGUCHINWILLJREIDJetal.Developmentof amasterslaverobotsystemfarmoperations[J].computers&Electronicsin A-griculture, 2004, 44(1):1-19.
[3] LIU Z, DHAMANkAR S, EVANS J T, et al. Developmentand experi-mentalvalidationa systemagricultural grainunloading-on-the-go[J]. computers andElectronics inAgriculture2022, 198: 107 005.
[4] Wang Jin, Dong Weimin, Tsui Ke, et al. __Electric control system for grain unloading and self-correcting grain unloading controlmethod: CN106576579 B [P]. 2019-03-12.
[5] Yao Jingfa, Teng Guifa, Huo Limin, et al.combine harvesterdiameter [J].
Agricultural Engineering, 2019 ,35(17):12-18.
[6] Cao Ruyue, Zhang Zhengan, Li Shichao, et al. Based on improved A* algorithm andBeziercurvemulti-machine cooperation [J]. Journal of Agricultural Machinery, 2021,52 (suppl1):548-554.
[7] Gong Jinliang, Wang Wei, Zhang Yanfei, et al. Cooperative operation of agricultural robot group based on farmland environmentindustry strategy [J]. Journal of Agricultural Engineering, 2021,37(2):11-19.
[8] ZHANG k B W, DENG C, OU YL.Design of multi-vehicle followingcontrol system based on arduino[J]. International Journal o 『computerApplications2016, 140: 5-8.
[9] Li Shichao, Cao Ruyue, Wei Shuang, et al. Based onTD-LTEmulti-machine cooperative navigation communication systemSystem [J]. Journal of Agricultural Machinery, 2017,48(suppl1):45-51.
[10] ZHANGWYHULWDINGFetal.Parkingprecisealignmentcontrol andcotransportersystem for rice harvesterandtransporter[J].computers and Electronics inAgriculture, 2023, 215:108 443.
[11]CUIZHUJYUYetal.Automaticgrainunloadingmethod
track-driven rice combine harvesters based onstereovision[J].com-puters and Electronics inAgriculture, 2024, 220:108 917.
[12] DING F, ZHANG W, LUO Xetal.Designandexperimentinter-vehiclecommunication basedondead-reckoninganddelaycompen-sation in a cooperative harvester and transportsystem[J]. Agriculture2022,12(12): 2 052.
[13] ZHANGCNOGUCHINYANGL.Leader-followersystemusingtwo robot tractors to improve workefficiency[J].computersandElec-tronics inAgriculture, 2016, 221: 269. -281.
[14] Bai Xiaoping, Wang Zhuo, Hu Jingtao, et al. Combine harvester group based on pilot-following structurecooperative navigation control method [J]. Journal of Agricultural Machinery, 2017,48(7):14-21.
[15]Zhang Wenyu, Zhang Zhigang, Luo Xiwen, et al. Longitudinal relative position speed of harvester and grain truckcoupling cooperative control method and experiment [J]. Journal of Agricultural Engineering, 2021,37(9):1-11.
[16] DINGFZHANGWYLUOXWetal.Gainself-adjustingsingleneuronPIDcontrolmethodandexperimentslongitudinalrelativepositionharvesterandtransportvehicle[J]. computers and Electron-ics inAgriculture, 2023, 213:108 215.
[17]LISCZHANGMWANGNetal.Intelligentschedulingmethodmulti-machinecooperativeoperationbasedon NSGA-III andimproved ant colony algorithm[J]. computers and Electronics inAgri-culture, 2023, 204:107532.
[18]WANGNLISCXIAOJetal.AcollaborativeSChedulingandplanning method for multiple machinesin harvestingandtransporta-tionoperations-partII:Schedulingandplanningharvestersandgrain trucks[J]. computers and Electronics inAgriculture, 2025, 235:110 344.
[19]Man Zhongxian, He Jie, Liu Shanqi, et al. Intelligent agricultural machinery multi-machine collaborative harvest operation control method.and experiment [J]. Journal of Agricultural Engineering, 2024,40(1):17-26.
[20]Zhang Wenyu, Zhang Zhigang, Zhang Fan, et al. Rice harvest and transport two-machine cooperative autonomous operation strategy.and experiment [J]. Journal of Agricultural Engineering, 2022,38(15):1-9.
[21] DINGFLUO X WZHANGZGetal.Dual-unloadingmodeau-tonomousoperationstrategyandcotransportersystem for rice harvesterand transporter[J].Engineering2024.
ResearchprogressonkeyTechnologyof RiceIntelligentHarvesting
ZHANGWenyu1,2,3,WUSijin1,ZHANGZhigang1,2,3,DINGFan1,2,3,HEJie1,2,3,HULian1,2,3,LUOXiwen1,2,3 *
(1SouthChinaAgriculturalUniversity/keyLaboratorySouthernAgriculturalMachineryandEquipmentkeyTechnologyMinistryEducationGuangzhou510642,China;2LingnanModernAgriculturalScienceandTechnologyLaboratoryGuangdongProvinceGuangzhou510032,China;
3GuangdongkeyLaboratoryof ArtificialIntelligenceinAgriculture,Guangzhou510642,China;*Correspondingauthor)
Abstract:continuous deepeningruralpopulationagingin China, it is urgent to enhance the intelligence levelriceproduction. Among variousproductionstagesdemandintelligenceinharvestingprocessisparticularlypressingandchallengingachieve.Currentlyduelimitedcapacitygrainbinsinintelligentriceharvestersfrequentunloadingisrequiredoperationswhichsignificantlyimpactsoperationalefficiency.addressthisissuethispapersystematicallyreviewsresearch progress on keytechnologiesof twocollaborativeoperationmodesnamelyfixed -pointunloadingandvehicle -followingunloadingintegratingcurrentresearchstatushomeandabroad.Intermsfixed-pointunloadingtechnologythroughapplication of high -precision spatial geometric modeling, parkingdistancecompensationprediction, andstereovisiondetectiontechnologyprecisealignmentlongitudinaldeviationless0.20mandlateraldeviationless0.10mhasbeenachievedeffectivelyimprovingaccuracyandefficiencyunloading.Inaspectvehicle-followingunloadingtechnologybasedon
(Go No. 70page)
Research and practice on High yieldFormationandcultivationTechniquesof Riceincoastalsaline-AlkaliLand
WEIHuanhe1,MENGTianyao2,cHENyinglong1,ZuOWengang3,yAORongjiang4,GAOpinglei1,Xuke1,ZHANGHongcheng1,DAIQigen1 *
(1JiangsukeyLaboratorycropGeneticsandphysiology/JiangsukeyLaboratorycropcultivationandphysiologyJiangsu/co-InnovationcenterforModernproductionTechnologyGraincrops/ResearchInstituteRiceIndustrialEngineeringTechnologyyangzhouuniversity/keyLaboratoryofsaline-AlkalisoilReclamationandutilizationincoastalAreasMinistryAgricultureandRuralAffairschina/EastchinaBranchNationalcenterTechnologyInnovationsaline-AlkaliTolerantRiceyangzhouJiangsu225009,china;2JointInternationalResearchLaboratoryofAgri-cultureandAgro-productsafetyMinistryEducation&yangzhouuniversity/InstituteAgriculturalscienceandTechnologicalDevelopmentyangzhouuniversityyangzhouJiangsu225009,china;3collegeEnvironmentalscienceandEngineeringyangzhouuniversityyangzhouJiangsu225009,china;4Instituteof soilsciencechineseAcademyof sciencesNanjing210008,china; 1stauthor:006931@yzu.edu.cn;*correspondingauthor:qgdai@yzu.edu.cn)
Abstract: china isactivelypromotingdevelopmentandutilizationcoastal saline -alkalilandvigorouslyexpandriceproduction. In view of the practical issues in rice production oncoastalsaline-alkali landsuchlowandunstableyieldsandunclearhigh-yieldcultivationtechniqueswehavesystematicallysummarizedourteam'sresearchandpracticalworkonformationhigh-yieldriceandcorrespondingcultivationtechniquesincoastalsaline-alkaliland.lawsgoverningformationhigh-yieldriceincoastalsaline-alkalilandaremainlymanifestedinfollowingthree aspects: (1) Ensuring an adequate number ofpaniclesperunit area with relatively large panicle size to collaboratively achieve a sufficient sink capacity of the population andmaintainahighdegreesinkfilling;(2)stabilizingearly-stagegrowthricereasonablyincreasingmid-stagephotosyntheticgrowthandsignificantlyenhancingdrymatteraccumulationcapacityinthelatestage; (3)Relyingongoodplantarchitectureandpopulationsupportensurethatsinkcapacitypopulationcanbefullyfilledgrains. Basedontheselawswehaveconductedaseriestargetedstudiesonhigh-yieldcultivationtechniquesriceincoastalsaline-alkalilandcoveringsuchkeytechnologiessoildesalinationkeytechnologiessoilfertilizationimprovementscreeningandidentificationsalt-tolerantricevarietiesappropriatedensity-fertilizercombinationsandbrackishwaterirrigationtechniques,wellapplicationexogenousgrowthregulators. Onthis basiswe have integrated and developed a rapid and efficient desalination and fertilization improvementtechniquethatcombinesmultiplecycles“plowingsunningsoakingrotarytillinganddraining”withapplicationorganicfertilizerswellacomprehensivemechanicaltransplantationcultivationtechniquecharacterizedusesalt-tolerantandhigh-qualityvarietiesandpracticesof “early sowing, frequent irrigation, strongseedlingsdenseplantingandsufficientfertilization.”Through the integratedapplicationthesetechniquesacomplete sethigh-qualityhigh-yield, and efficientmechanicaltransplantation cultivation techniquesrice in coastalsaline-alkali land has been established, achieving remarkableeffectsinsoilimprovementandyieldincreaseoncoastalsaline-alkaliland.
keywords:coastalsaline-alkaliland;rice;yieldformation;high-yieldcultivationtechniques
(62 abovepage)
improvedinter-machinecommunicationprotocol(utilizingradio/4Gdual-mode)andkalmanfilterdelaycompensationmethodcommunicationerrorhasbeensuccessfullyreducedover82.00 percent.Meanwhilecombinedgainself-adjustingsingle-neuroncontrol algorithm, the dynamic collaborative longitudinal deviation is stably controlled within ±0.08 msignificantlyenhancingstabilityandreliabilityvehicle-followingunloading.Regardingpathplanning,thispaperconstructsamulti-objectiveoptimizationmodelbasedonimprovedantcolonyalgorithm.simulationresultsindicatethatadoptionof this model canimprovecollaborativeoperationefficiency13.58 percent,furtheroptimizingharvestingprocess.integratingaforementionedtechnologiesconstructedcollaborativesystemenablesariceharvestingefficiency0.42hectaresperhourrepresentinga26.00 percentincreasecomparedto single-machine operations. However, existing research still has certain limitations in termsadaptability to complexfarmlandenvironmentsandapplicabilityirregularplots.Infutureitisnecessaryfurtherstrengthensystem/srobustnessandconductmulti-scenariovalidationpromotewidespreadapplicationanddevelopmentintelligentriceharvestingtechnology.keywords:rice;intelligentharvesting;high-precisionalignment;collaborativeunloading;pathplanning;inter-machinecommunication;unmannedfarm
